Drone firmware and telemetry
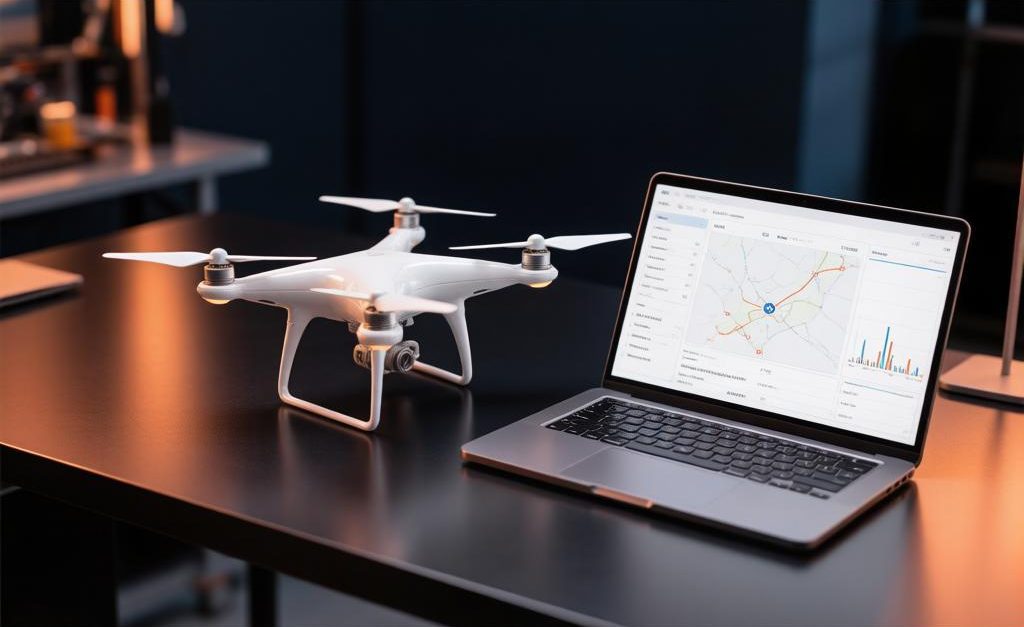
A PX4 flight controller: waypoint missions, position hold and return‑to‑home on link loss. MQTT telemetry streams to a live web map dashboard.
Task
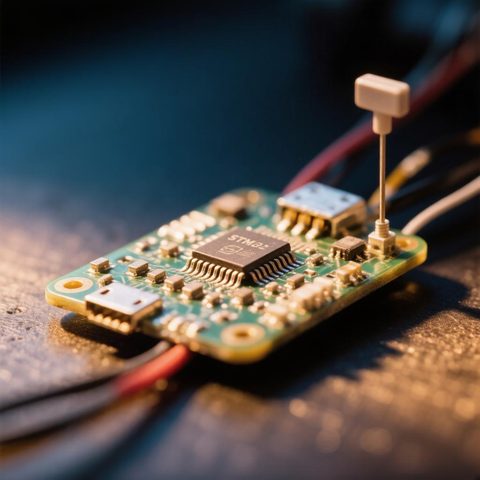
In‑house R&D: flight controller firmware and telemetry to follow the drone in a browser.
We wanted to build the whole chain ourselves, from code on the board to an operator dashboard showing the drone’s position and status in real time.
Solution
PX4 flight controller
The firmware is built on the open PX4 flight stack and adapted to our task.
Waypoint missions
The operator marks points on the map and the drone flies the route on its own.
Position hold
The drone holds a set position in the air without constant commands from the operator.
Return‑to‑home
If the link is lost, the drone flies back to the take‑off point by itself.
MQTT telemetry
Coordinates, altitude and system status are streamed over MQTT in real time.
Web dashboard with a map
The operator follows the flight in an ordinary browser: the drone on the map, data updating live.
Hardware and software
STM32 and ESP32 controllers, ROS 2 and C++ code.
Result
PX4
flight stack
MQTT
live telemetry
Home
return on link loss
The drone flies its route and returns home on link loss, and the whole flight is visible in a browser in real time.
Palette
Click a colour to copy its HEX
Technologies
 PX4
 STM32
 ESP32
 C++
 ROS 2
 MQTT
Memberships with online payment and receipts, a personal account and live classes with recordings on our own video server, no Zoom or YouTube. Memberships are spread over the schedule automatically.
View case